Autonomous Aerial CPR Robot
A flying robotic system designed to deliver immediate, high-quality Cardiopulmonary Resuscitation (CPR) to cardiac arrest victims in hard-to-reach locations. 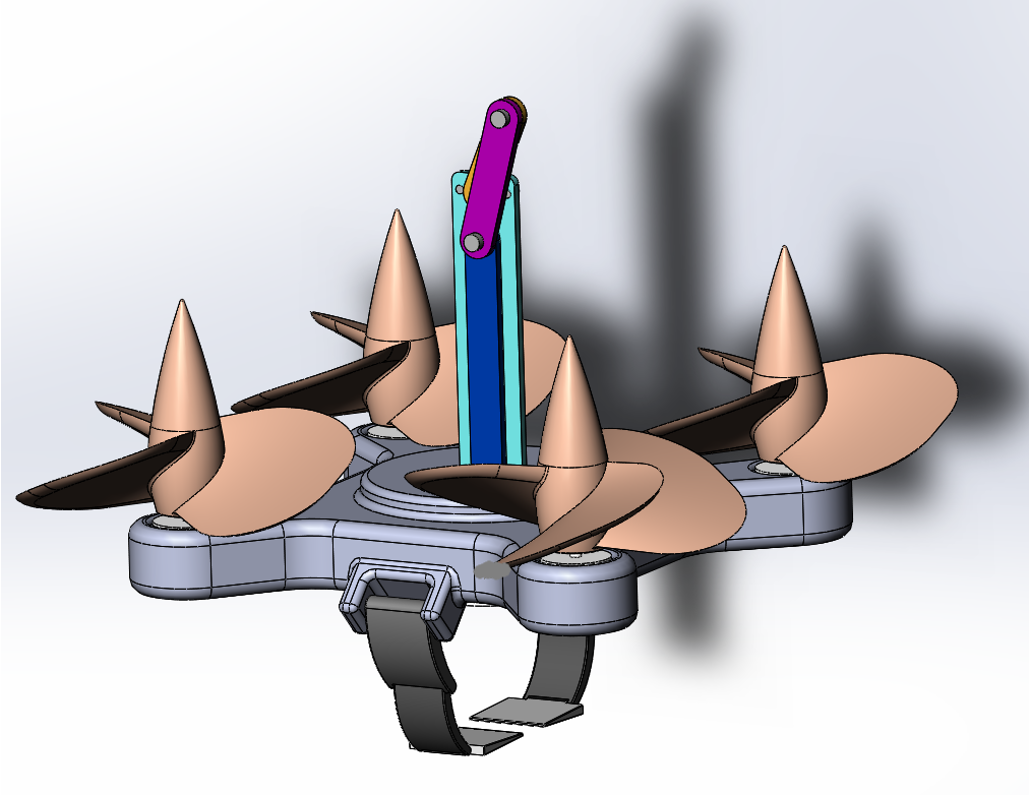

A flying robotic system designed to deliver immediate, high-quality Cardiopulmonary Resuscitation (CPR) to cardiac arrest victims in hard-to-reach locations.
A full-scene motion capture solution fusing Ultra-Wideband (UWB) positioning with Inertial Measurement Units (IMU) using Recurrent Neural Networks for precise rehabilitation monitoring. 
Investigating the physiological synergy between the cardiac and locomotor systems using a single chest-mounted Inertial Measurement Unit (IMU). 
A 2.14 mm OD hydraulically actuated soft robot designed for minimally invasive surgery, featuring a novel routing design to minimize twisting and hysteresis modeling for precise control. 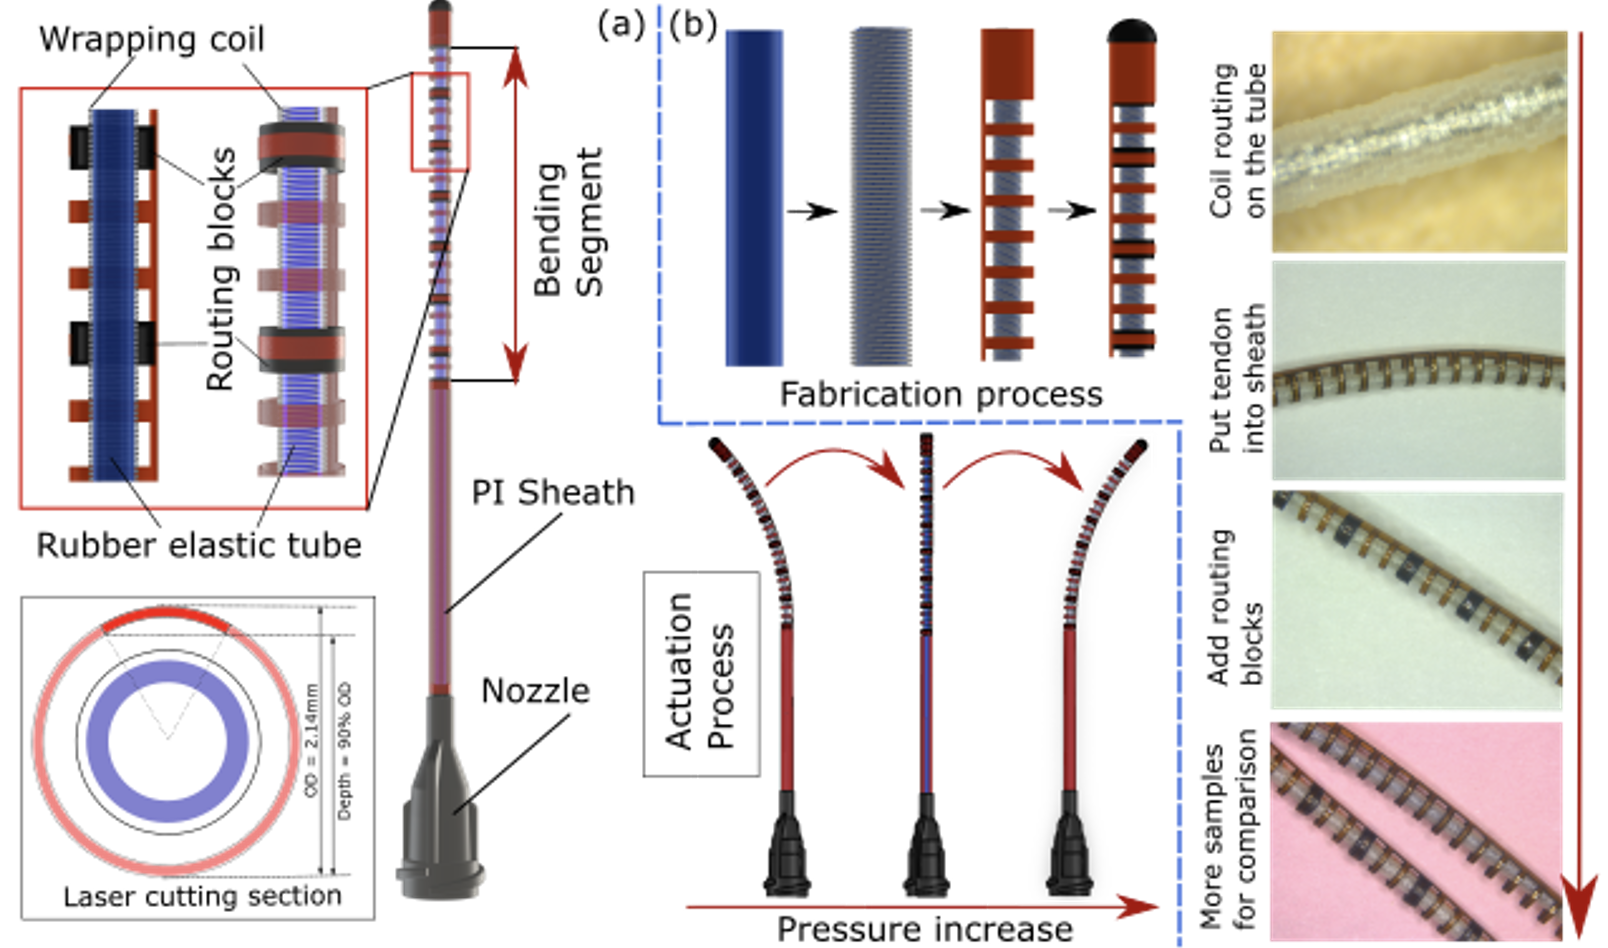
A wireless, high-precision inertial navigation system designed for the Direct Anterior Approach (DAA) in hip replacement surgeries. 
Published in Biomimetic Intelligence and Robotics, 2023
Recommended citation: Chenyu Gu, Weicong Lin, Xinyi He, Lei Zhang, Mingming Zhang, "IMU-based motion capture system for rehabilitation applications: A systematic review," Biomimetic Intelligence and Robotics, vol. 3, no. 2, p. 100097, 2023.
Download Paper
Published in Patents, 2024
Recommended citation: Li Guangheng, Zhang Mingming, Yu Yangyi, and Chenyu Gu. A joint replacement simulation device and a jointreplacement simulation method. China CN118634071A, filed July 9, 2024, and issued September 13, 2024.
Published in Patents, 2024
Recommended citation: Zhang Mingming, and Chenyu Gu. Human motion capture method, system and storage medium. China CN118870291A, filed July 9, 2024, and issued October 29, 2024.
Published in IEEE Transactions on Instrumentation and Measurement, 2025
Recommended citation: C. Gu et al., "A Portable Inertial Navigation System for Total Hip Arthroplasty Targeting Direct Anterior Approach," in
Download Paper
Published in International Symposium on Medical Robotics (ISMR), 2026
Recommended citation: C. Gu, T. A. Brumfiel, N. Malhotra, and J. P. Desai, “Design and Modeling of a Polymer-based Hydraulic Continuum Robot for Minimal Invasive Surgery,” International Symposium on Medical Robotics (ISMR), 2026. (Best Student Paper Award)
Graduate Teaching Assistant, Georgia Institute of Technology, College of Computing, 2025